
Introduction to Autonomous Robots Mechanisms, Sensors, Actuators, and Algorithms
, by Correll, Nikolaus; Hayes, Bradley; Heckman, Christoffer; Roncone, Alessandro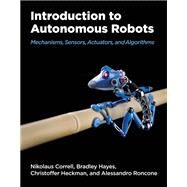
- ISBN: 9780262047555 | 0262047551
- Cover: Hardcover
- Copyright: 12/20/2022
A comprehensive introduction to the field of autonomous robotics aimed at upper-level undergraduates and offering additional online resources.
Textbooks that provide a broad algorithmic perspective on the mechanics and dynamics of robots almost unfailingly serve students at the graduate level. Introduction to Autonomous Robots offers a much-needed resource for teaching third- and fourth-year undergraduates the computational fundamentals behind the design and control of autonomous robots. The authors use a class-tested and accessible approach to present progressive, step-by-step development concepts, alongside a wide range of real-world examples and fundamental concepts in mechanisms, sensing and actuation, computation, and uncertainty. Throughout, the authors balance the impact of hardware (mechanism, sensor, actuator) and software (algorithms) in teaching robot autonomy.
Features:
Rigorous and tested in the classroom Written for engineering and computer science undergraduates with a sophomore-level understanding of linear algebra, probability theory, trigonometry, and statistics QR codes in the text guide readers to online lecture videos and animations Topics include: basic concepts in robotic mechanisms like locomotion and grasping, plus the resulting forces; operation principles of sensors and actuators; basic algorithms for vision and feature detection; an introduction to artificial neural networks, including convolutional and recurrent variants Extensive appendices focus on project-based curricula, pertinent areas of mathematics, backpropagation, writing a research paper, and other topics A growing library of exercises in an open-source, platform-independent simulation (Webots)
Textbooks that provide a broad algorithmic perspective on the mechanics and dynamics of robots almost unfailingly serve students at the graduate level. Introduction to Autonomous Robots offers a much-needed resource for teaching third- and fourth-year undergraduates the computational fundamentals behind the design and control of autonomous robots. The authors use a class-tested and accessible approach to present progressive, step-by-step development concepts, alongside a wide range of real-world examples and fundamental concepts in mechanisms, sensing and actuation, computation, and uncertainty. Throughout, the authors balance the impact of hardware (mechanism, sensor, actuator) and software (algorithms) in teaching robot autonomy.
Features:

Please wait while the item is added to your bag...

Review